소개
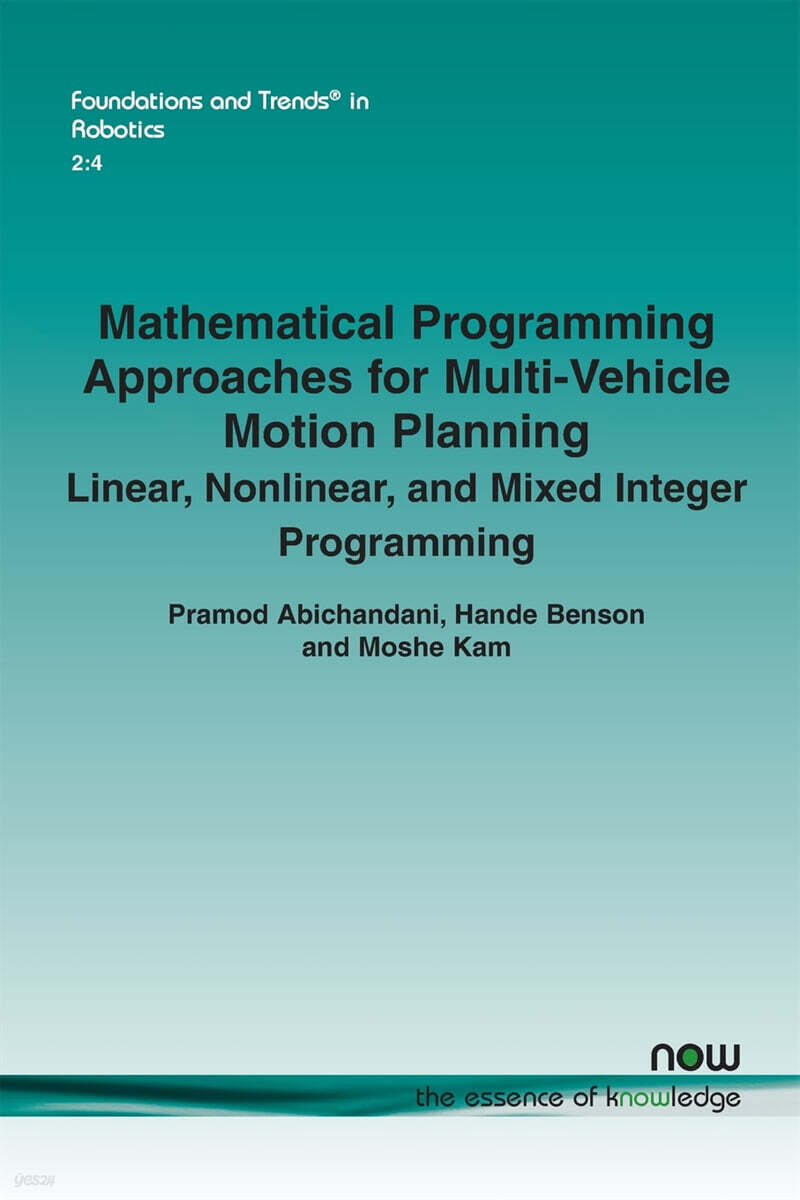
Real world Multi-Vehicle Motion Planning (MVMP) problems require the optimization of suitable performance measures under an array of complex and challenging constraints involving kinematics, dynamics, collision avoidance, and communication connectivity. The general MVMP problem is thus formulated as a Mathematical Programming (Optimization) problem. This book presents a Mathematical Programming (MP) framework that captures the salient features of the general MVMP problem.